



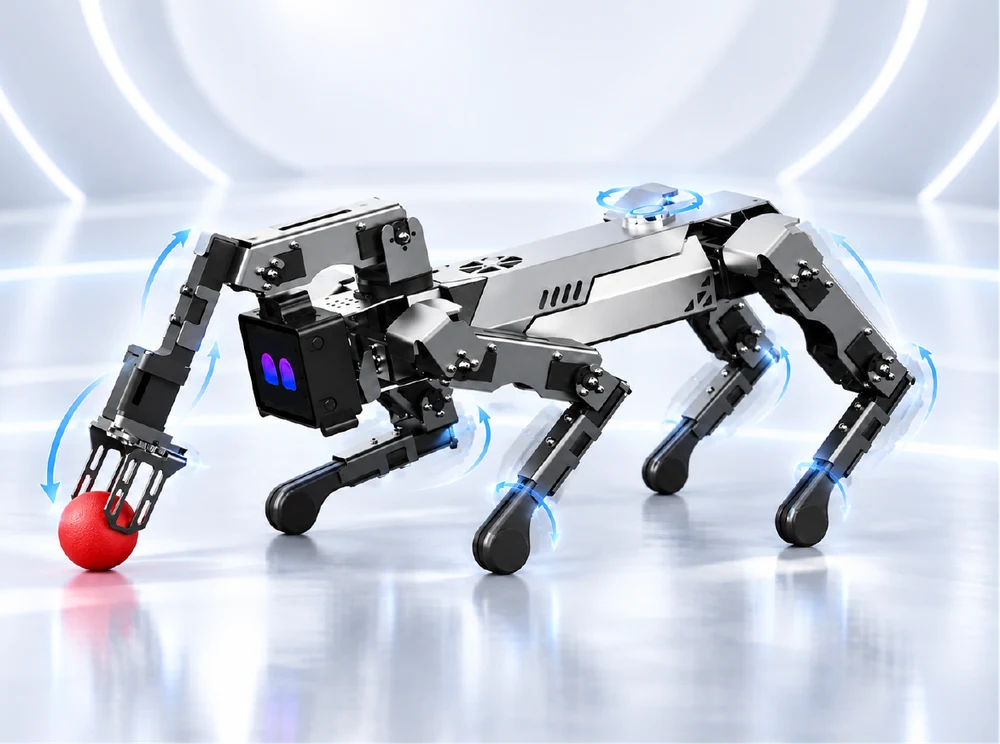
16-DOF whole-body coordination
A 12-DOF quadruped base handles movement and posture, a 3-DOF arm performs grasping, and a 1-DOF turntable expands its reach. Approach, adjust and manipulate on a single platform.
- 12
- Leg joints
- 3
- Arm joints
- 1
- Turntable

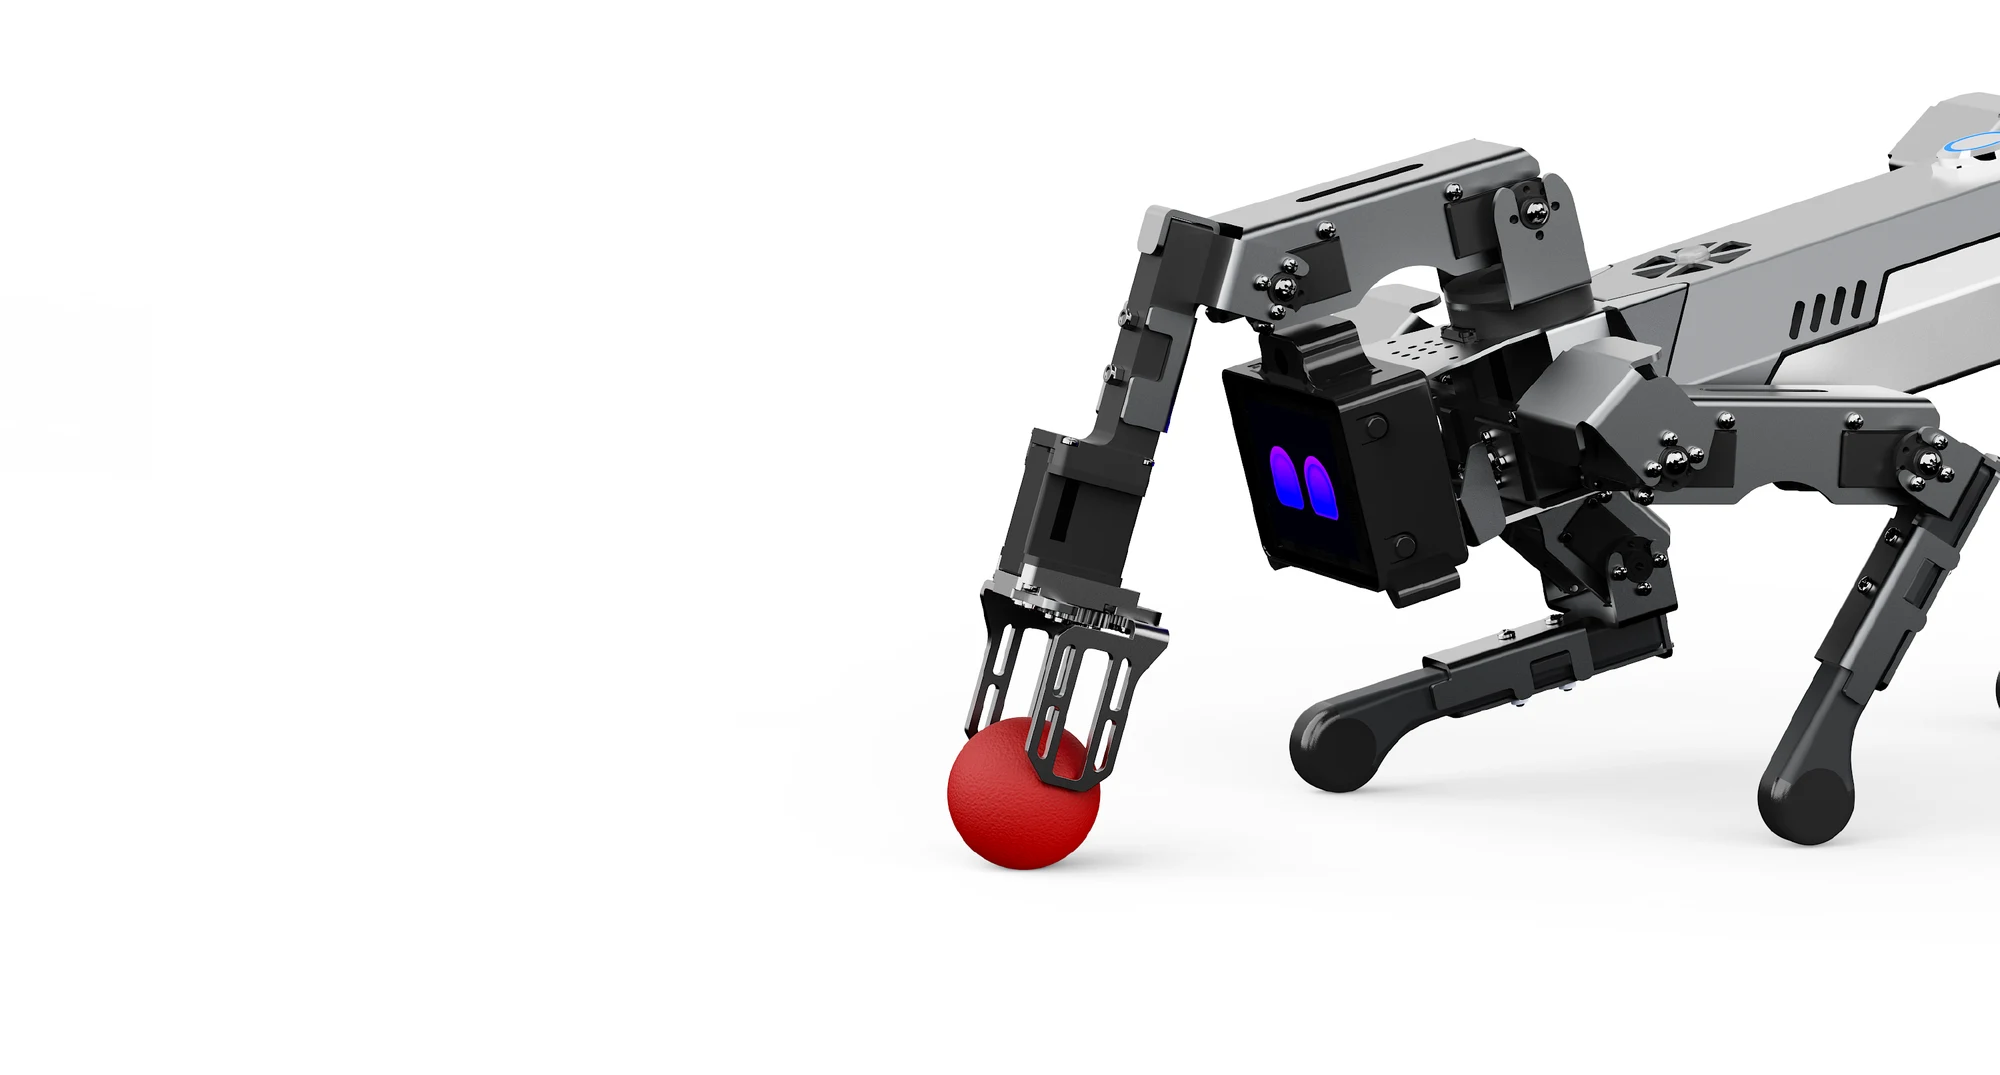
The all-in-one quadruped AI platform for makers
More computing power. More capability. An AI companion out of the box, a ROS lab when you connect.
More power, more capability. Open ROS development for university research, advanced projects and new discoveries.
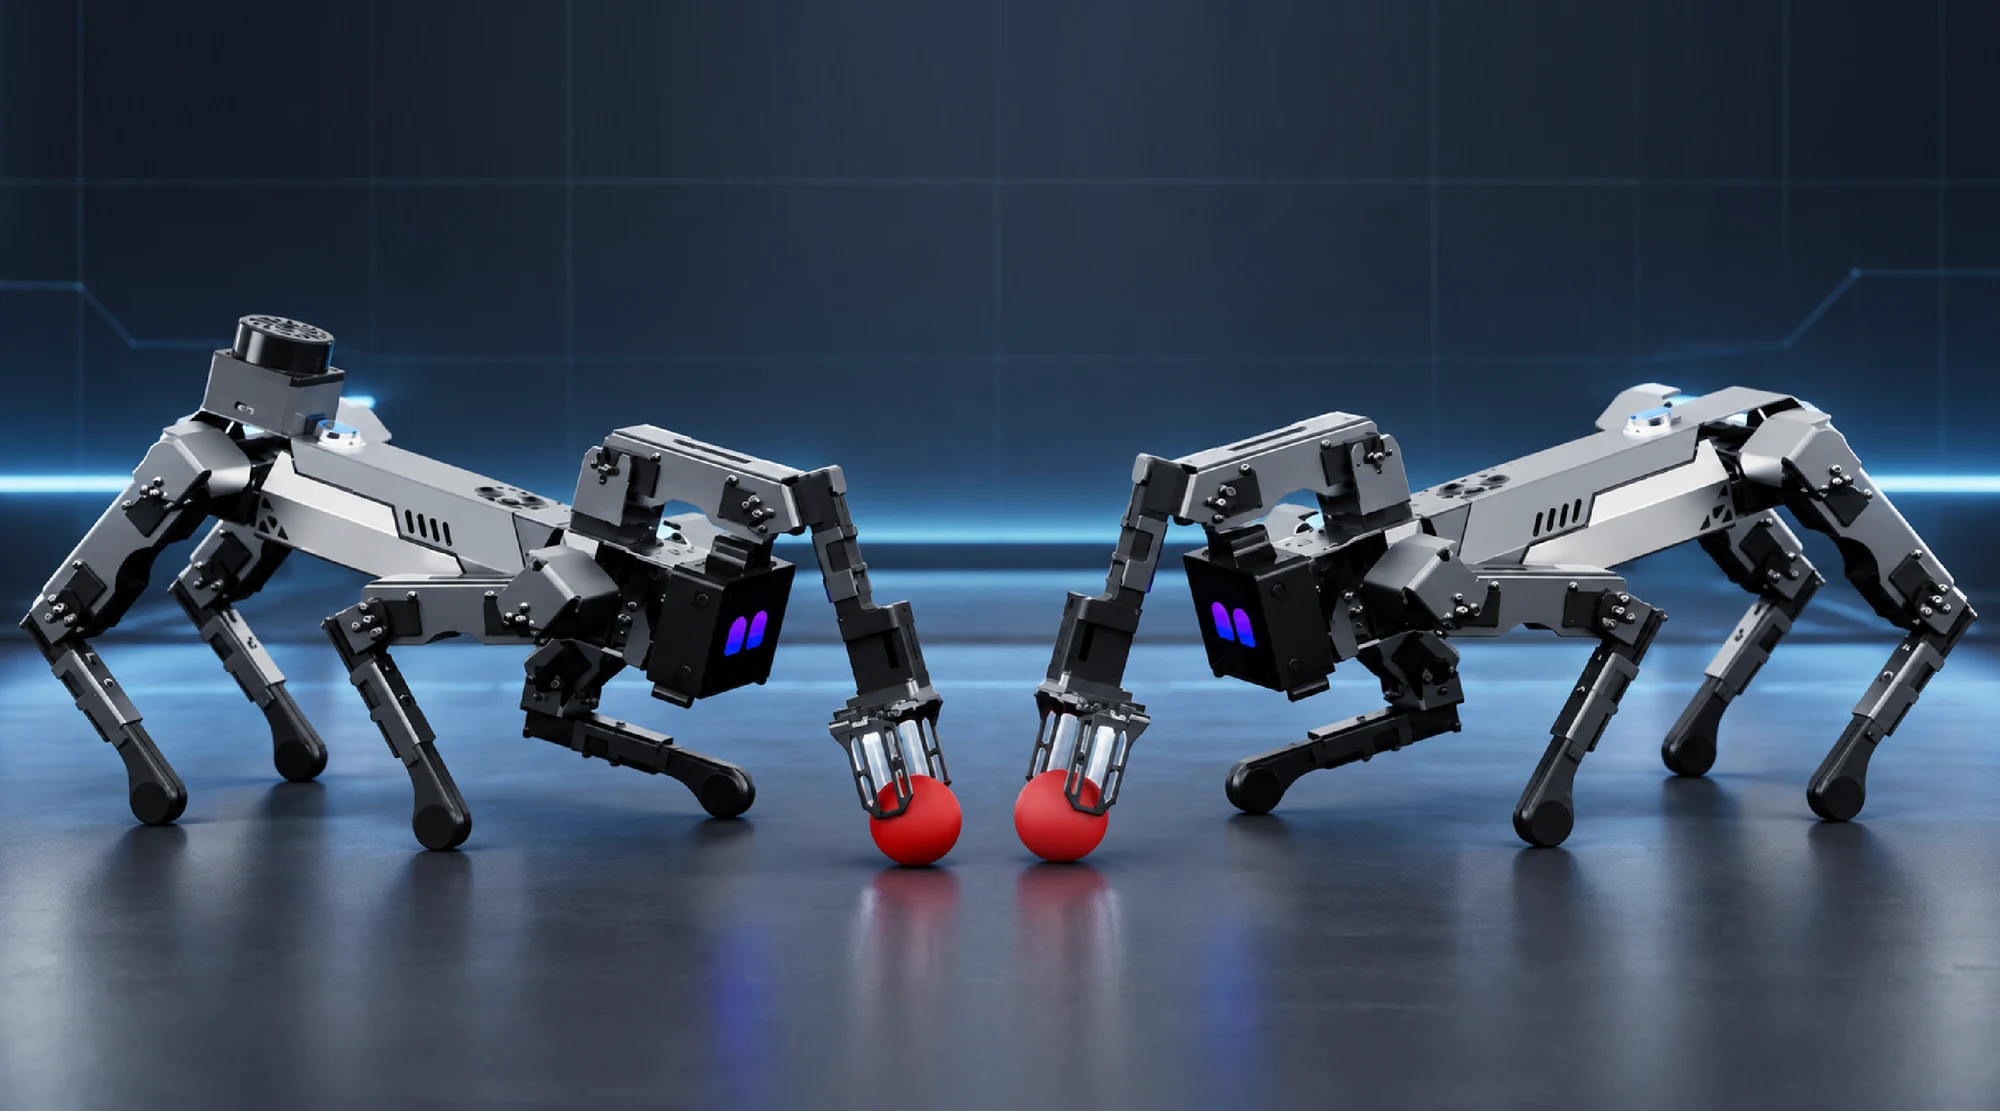
The standard edition focuses on embodied interaction and robot development. The LiDAR edition adds environmental scanning for spatial perception and mobile robotics research.
From whole-body motion and joint feedback to edge computing, Mini2S brings mobility, manipulation and AI together.
A 12-DOF quadruped base handles movement and posture, a 3-DOF arm performs grasping, and a 1-DOF turntable expands its reach. Approach, adjust and manipulate on a single platform.
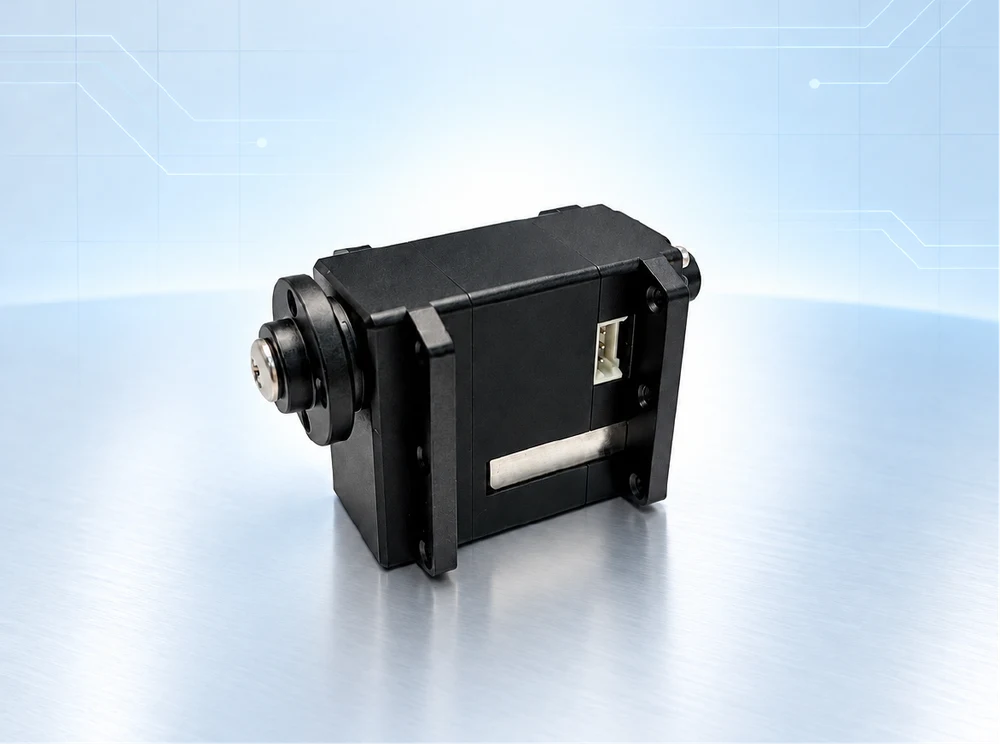
Coreless motors deliver 4.5 kg·cm of torque, with magnetic encoders reporting joint angles to 0.01°. Continuous 0–360° rotation combines range with fine control and supports manual teaching.
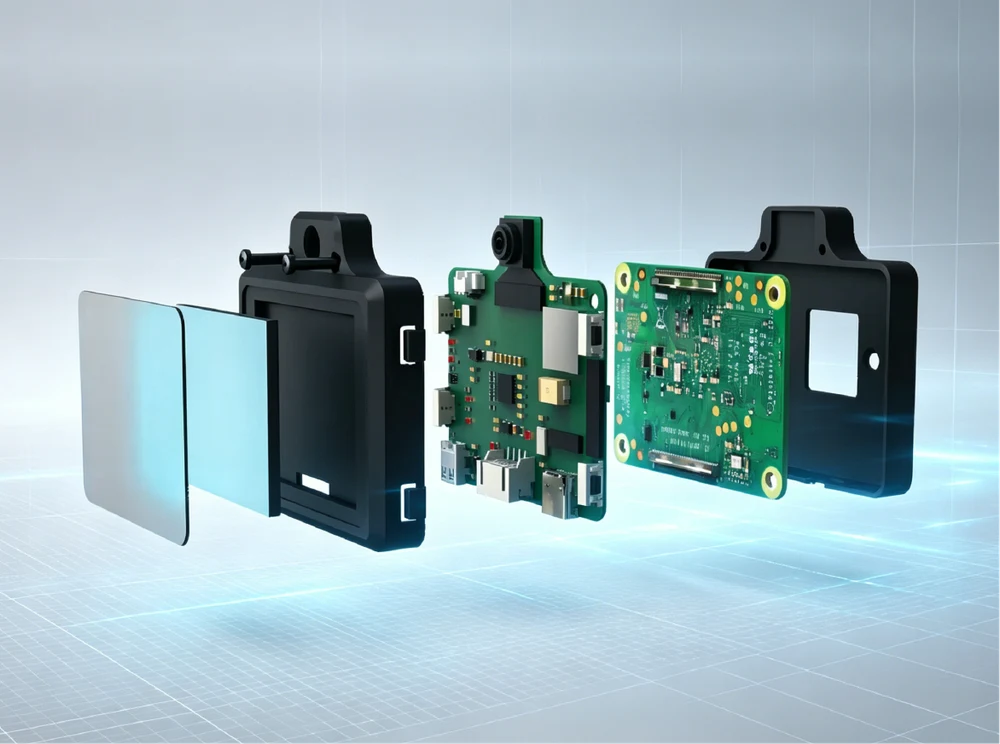
The XGO AI head module integrates a Raspberry Pi CM5 with 4GB RAM and 32GB storage, running Luwu-OS. Run AI demos, vision tasks and large-model interactions without an external PC.
The 12-DOF mobile base handles movement, while the 4-DOF arm with turntable handles manipulation. One motion library coordinates both into a complete desktop mobile manipulator.
Omnidirectional control combines translation and turning
Coreless motors and magnetic encoders form a closed-loop actuation system for fast response, continuous rotation and fine control.
Extended rotational travel leaves room for complex movements.
Solid power for dynamic gaits and sensor payloads.
Real-time joint position feedback makes movements controllable and repeatable.
A 5MP camera captures images, dual microphones capture sound, and CM5 processes recognition and decisions locally—turning results into expressions, voice responses and physical actions.
Run face, gesture and color vision tasks with a continuous view of the environment.
CM5 enables edge computing, reduces cloud dependence and lets you bring your own models.
The display and speaker communicate recognition results and make interaction states clear.
Connect perception to locomotion and the arm to complete the sense–decide–act loop.
Built on Raspberry Pi CM5, Luwu-OS and open Python APIs. Develop and validate motion control, camera vision and ROS 2 nodes on the same platform.
# xgolib: discover the UART and robot model
from xgolib import XGO
from time import sleep

dog = XGO()
print("firmware:", dog.read_firmware())
dog.pace("high")

dog.move("x", 18)
sleep(1.2)
dog.move("y", -8)
sleep(0.8)
dog.turn(60)
sleep(1.0)

dog.stop()
dog.reset()
LUWU-OS API · xgolib automatically scans ttyAMA5 / ttyAMA0
# Track a blue target and turn using its horizontal offset
from picamera2 import Picamera2
from xgolib import XGO
import cv2, numpy as np

cam, dog = Picamera2(), XGO()
config = cam.create_preview_configuration(
    main={"size": (640, 480), "format": "RGB888"}
)
cam.configure(config)
cam.start()

while True:
    frame = cam.capture_array()
    hsv = cv2.cvtColor(frame, cv2.COLOR_RGB2HSV)
    mask = cv2.inRange(hsv, np.array([95, 90, 60]),
                              np.array([130, 255, 255]))
    m = cv2.moments(mask)
    if m["m00"] > 3000:
        cx = int(m["m10"] / m["m00"])
        dog.turn(int(np.clip((320 - cx) * 0.25, -60, 60)))
    else:
        dog.stop()
Vision pipeline · OV5647 → Picamera2 → OpenCV → xgolib
# Switch between simulation and hardware in one ROS 2 node
import rclpy
from rclpy.node import Node
from xgolib import XGO

class WalkNode(Node):
    def __init__(self):
        super().__init__("xgo_walk")
        self.declare_parameter("simulate", True)
        self.sim = self.get_parameter("simulate").value
        self.dog = None if self.sim else XGO()
        self.timer = self.create_timer(0.1, self.control)

    def control(self):
        speed = 18
        self.get_logger().info(f"cmd_x={speed} sim={self.sim}")
        if self.dog:
            self.dog.move("x", speed)

rclpy.init()
rclpy.spin(WalkNode())

# ros2 run xgo_demo walk --ros-args -p simulate:=true
Luwu ROS v0.1 · ROS 2 Lyrical example; simulation mode does not write to hardware
Automatically detect the device and UART. Build action sequences with public APIs including move, turn, pace, stop and reset.
Capture RGB images from OV5647, segment colors in HSV, locate targets and calculate offsets to drive robot following in real time.
The Luwu ROS image includes ROS 2 Lyrical, OpenCV, cv_bridge and basic examples, ready to extend into visualization, simulation and reinforcement learning workflows.
A high-performance lab that fits on your desk.